camsim
Deterministic camera sensor and ISP simulation with image-quality metrics.
camsim is a professional Python library that simulates a camera from spectral
scene irradiance to a rendered image and measures image quality with standard
metrics. It is built for camera and ISP engineers, and researchers who need a
reproducible, physically grounded testbed. Rendered images and IQ reports can
feed downstream computer-vision or ML experiments.
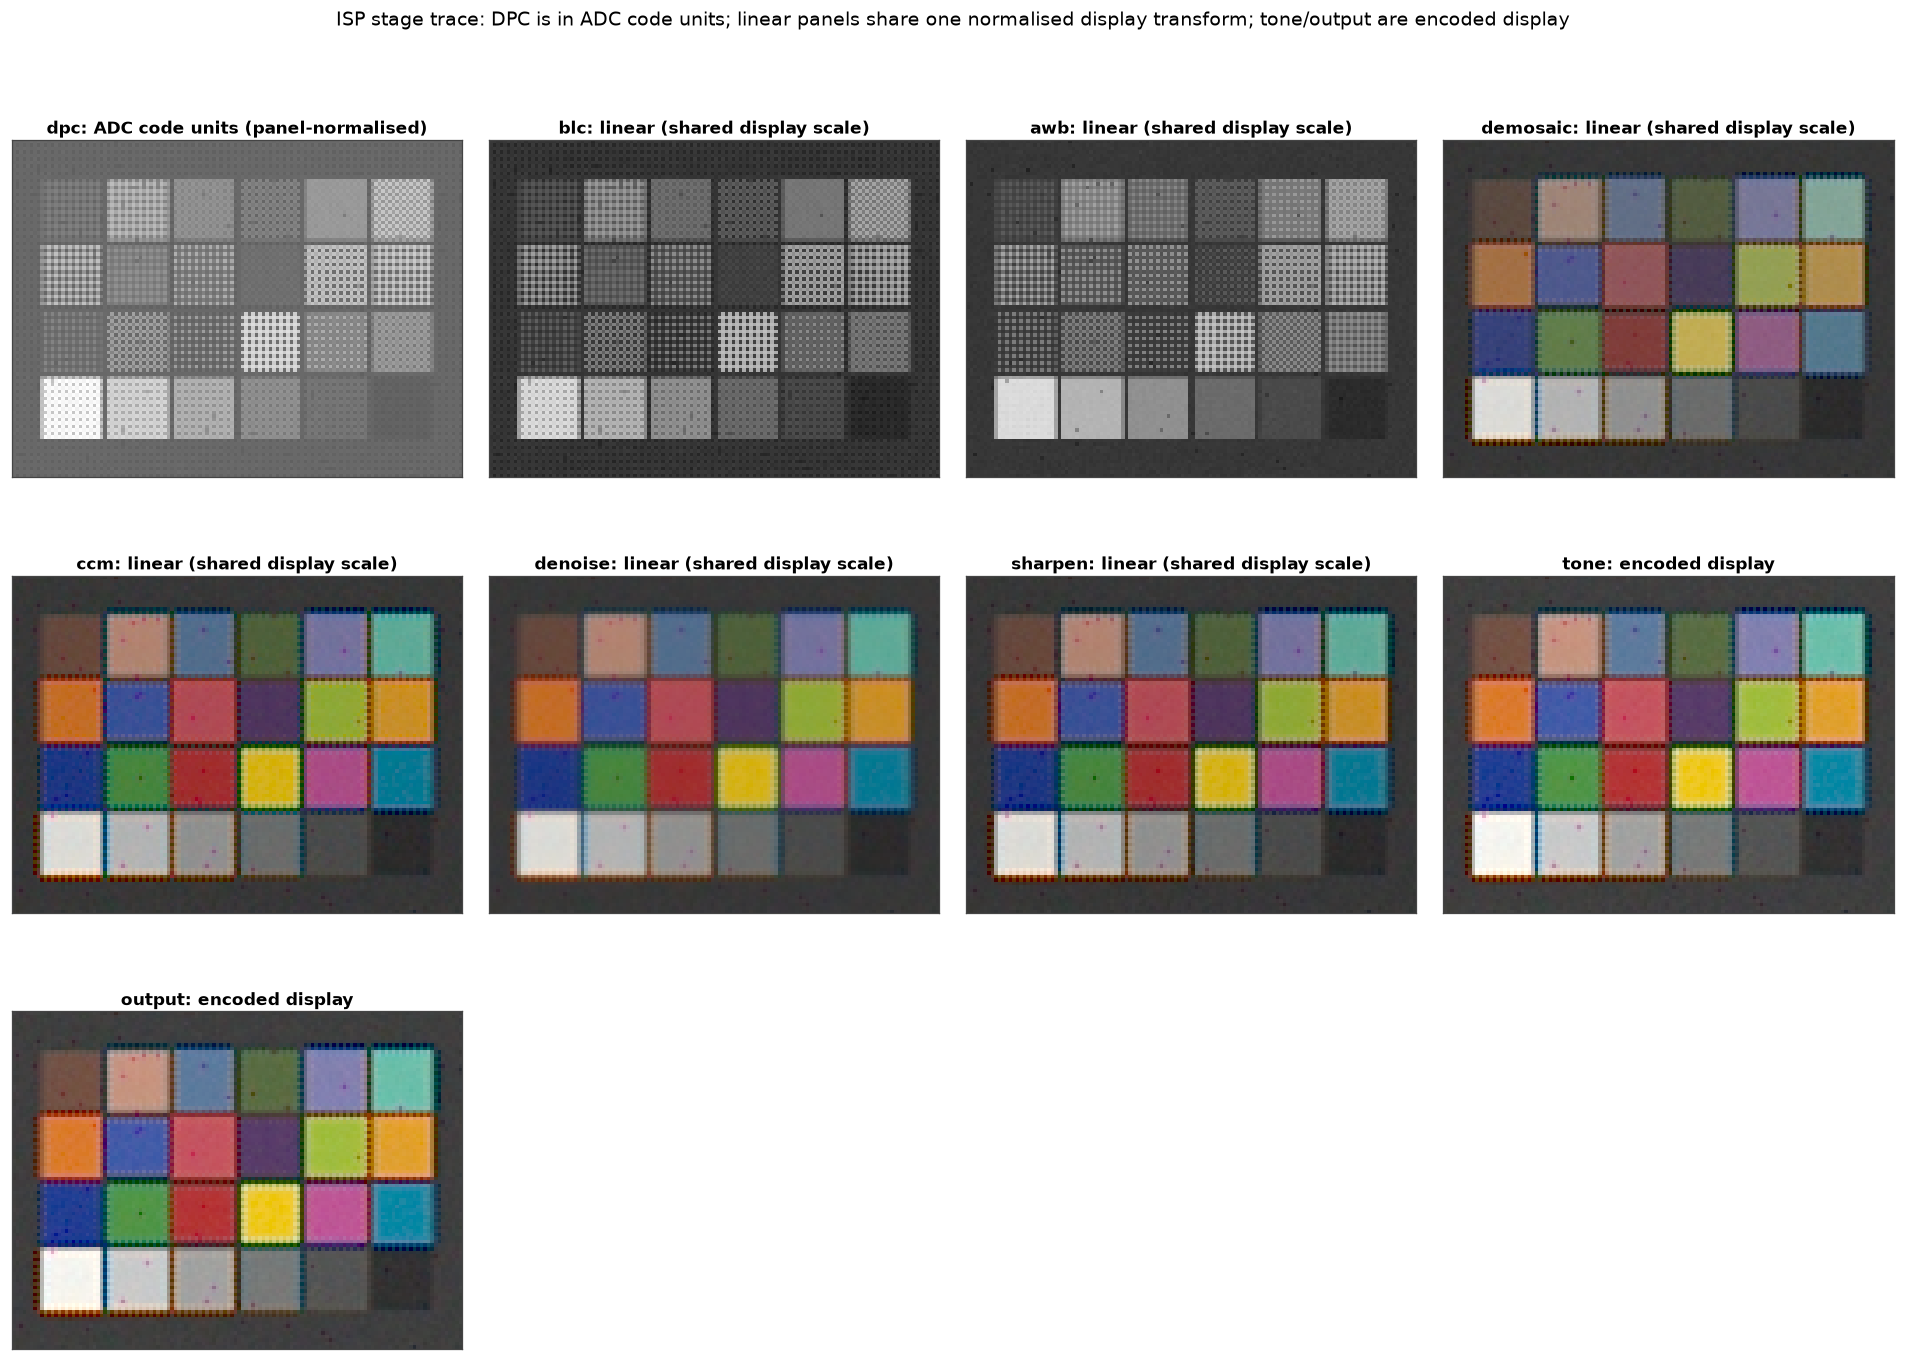
The default ISP applied to a spectral ColorChecker scene, shown stage by stage: RAW, defect correction, black-level correction, lens shading, white balance, demosaicing, colour correction, denoise, sharpen, and tone.
What's inside
- Simulation pipeline — spectral scene and optics helpers, a rigorous sensor model (irradiance → RAW), and a modular ISP (RAW → rendered image). The reusable core is the sensor + ISP pair; neither depends on the scene or optics packages.
- Image-quality metrics — an independent harness for e-SFR/MTF, SNR, colour error, and acutance. It operates on arrays plus metadata and never imports the simulator.
- Reproducible tooling — camera orchestration, RAW/image IO, CLI commands, and validated presets that make every result repeatable.
Install
With uv:
uv add camsim
Or with pip:
pip install camsim
For development:
git clone https://github.com/pengzhao-ai/camsim.git
cd camsim
uv sync --all-extras
pip/venv fallback:
python -m venv .venv
source .venv/bin/activate
python -m pip install --upgrade pip
pip install -e ".[all]"
Quick check
import camsim

print(camsim.__version__)
camsim info
End-to-end example
import camsim
from camsim.config.io import PRESETS_DIR, load_isp, load_sensor
from camsim.metrics import measure_all
from camsim.scene.charts import slanted_edge_layout
from camsim.scene.targets import render

scene = render("slanted_edge", lux=200.0, shape=(256, 256), oversampling=2, seed=11)
sensor = camsim.Sensor(
    load_sensor(PRESETS_DIR / "sensors" / "flagship_phone_50mp.json"), seed=1
)
raw = sensor.expose(scene.irradiance, exposure_s=0.01, mode="LCG", seed=7)
image = camsim.ISP(load_isp(PRESETS_DIR / "isp" / "default.json")).process(raw)
report = measure_all(image, slanted_edge_layout(shape=(256, 256)))

print(image.data.shape, image.color_space)
print(report.mtf.mtf50_cp, report.acutance)
Where to go next
- Concepts — the imaging chain, units, linear-space invariant, and determinism contract.
- Architecture — package layout, data contracts, and dependency rules.
- ISP stages — every stage's role, parameters, trace, and linear-space invariant.
- Metrics — chart layouts, e-SFR, SNR, colour, acutance, and the unified report.
- Validation — validation evidence, measured results, coverage policy, and reproduction commands.
- Datasheet mapping — how preset fields trace to public specifications.
- API reference — the public modules and types.
- Release process — versioning and publishing policy.